Tutorials
Tutorials, engineering notes, and field reports from building robotics applications with Robium.
7 posts
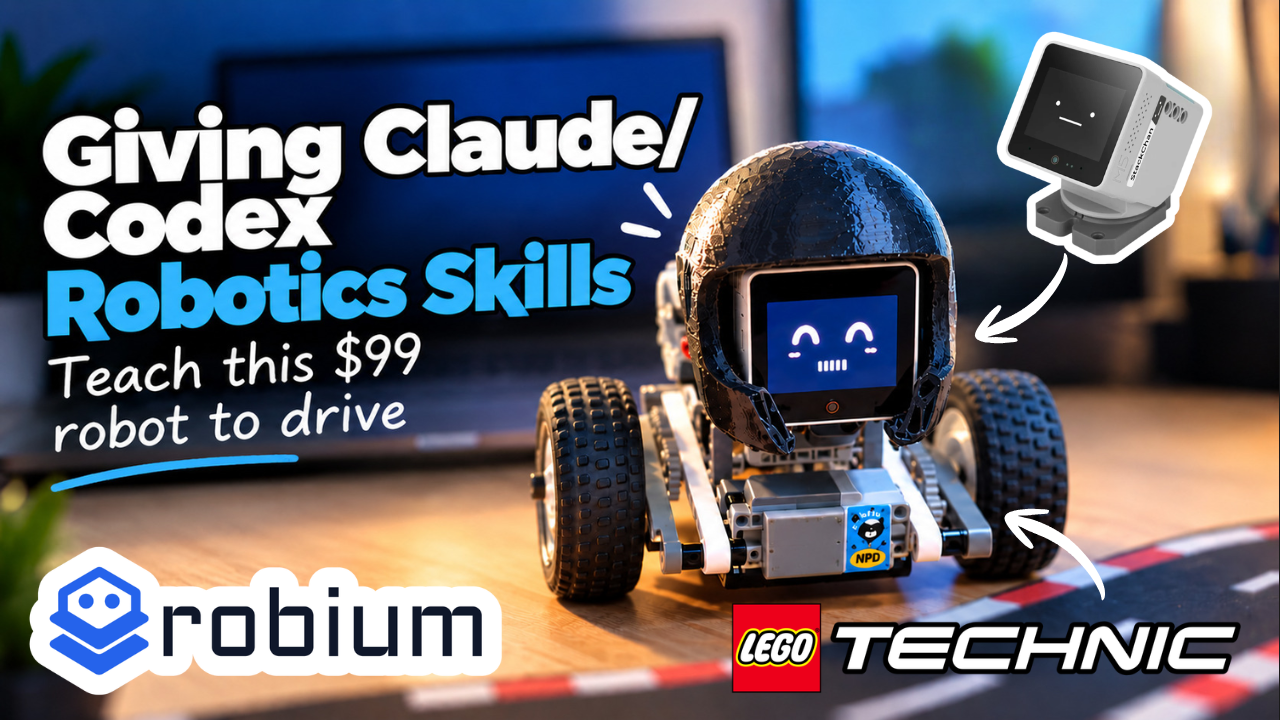
Teaching Stack Chan to drive with LEGO, Pybricks, and Robium
Stack Chan can see and speak, but it needed wheels. In lego-stackchan-drive, we added LEGO motors and taught it to follow lines and drive between guardrails.
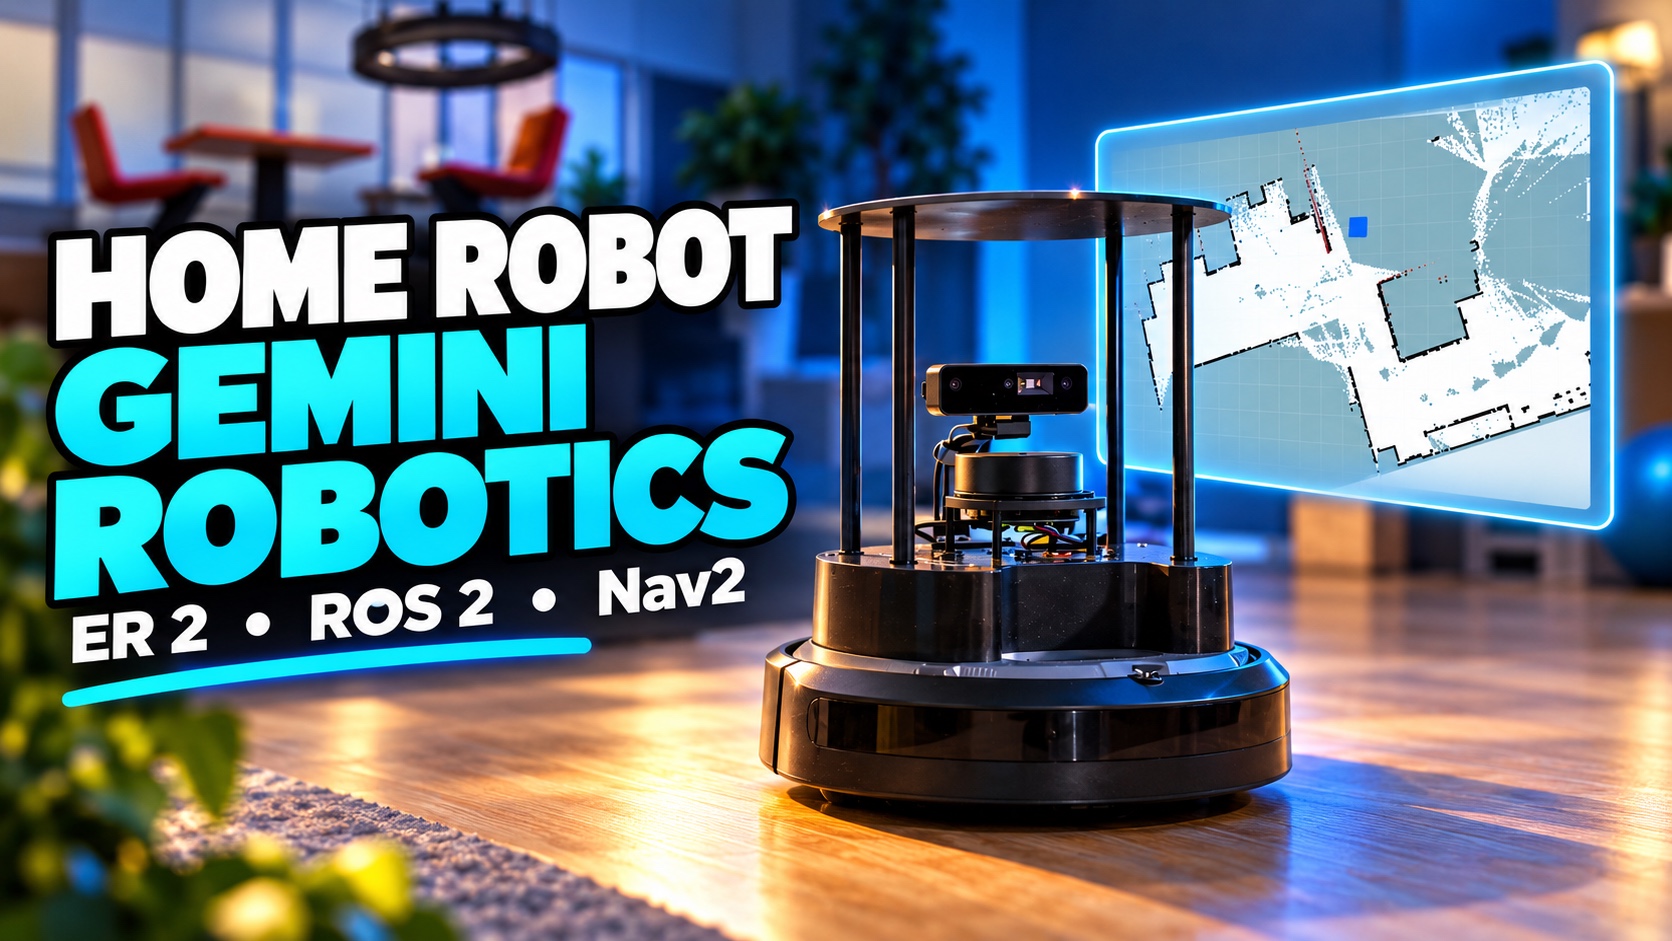
Building a mobile home robot with Gemini Robotics ER 2 and ROS 2 in under an hour
A TurtleBot 4 sends camera and robot state to Gemini Robotics ER 2, while a deterministic guard, ROS 2, and Nav2 stay in charge of motion.
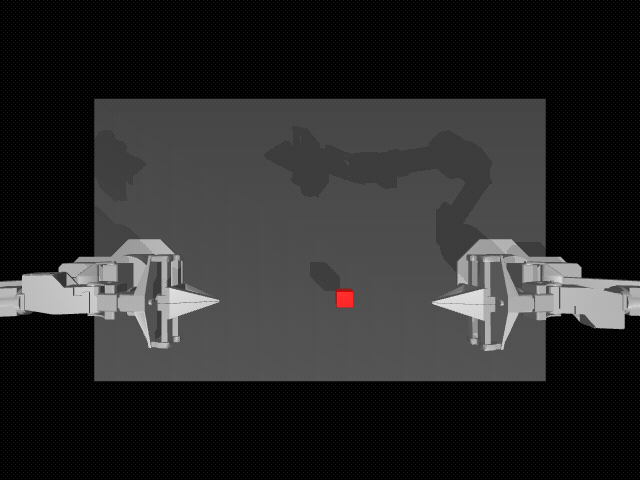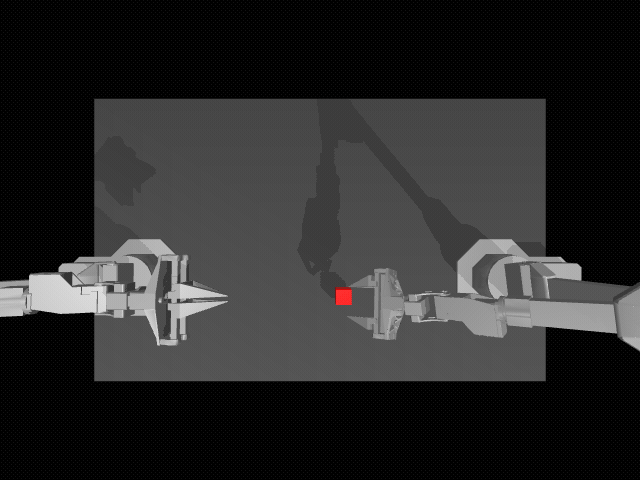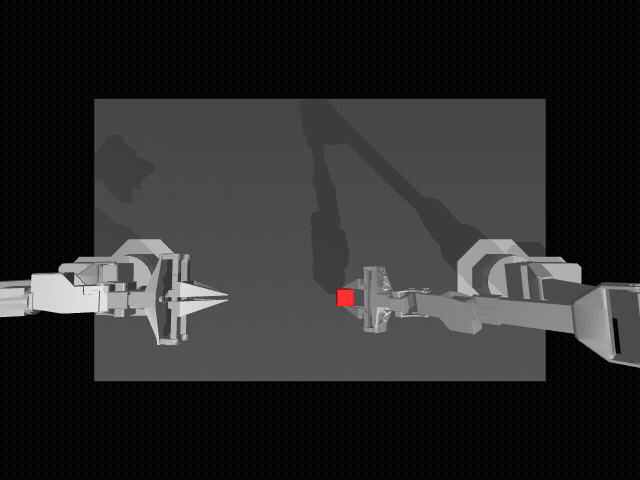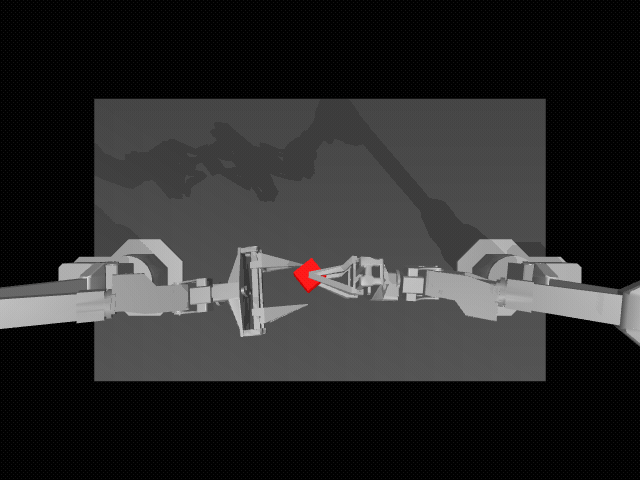
Training and running an ALOHA cube-transfer policy with ACT
Run the official ACT cube-transfer policy locally, see why action chunking mattered, and use the same workflow as a starting point for your own demonstrations.
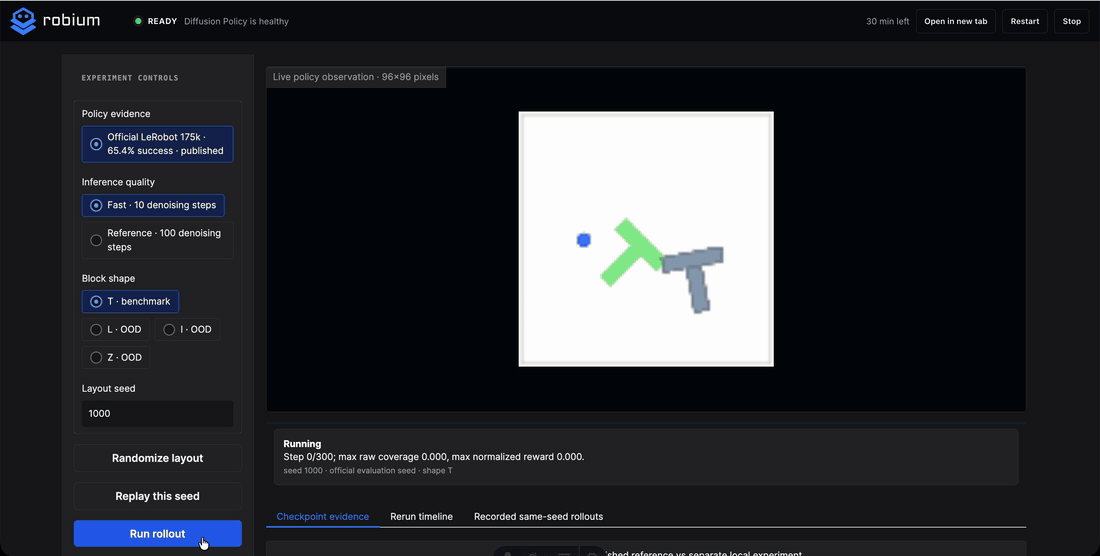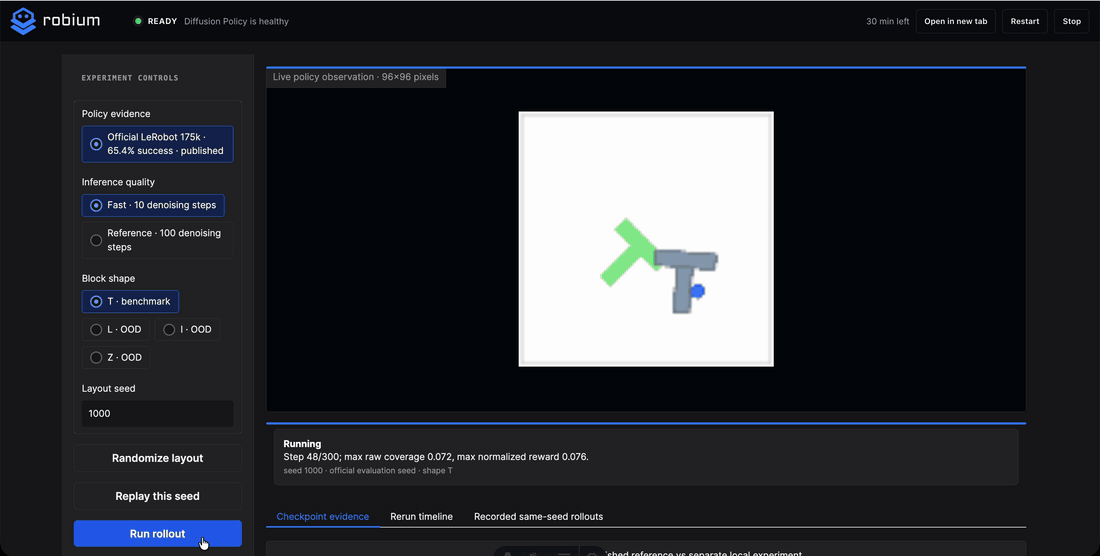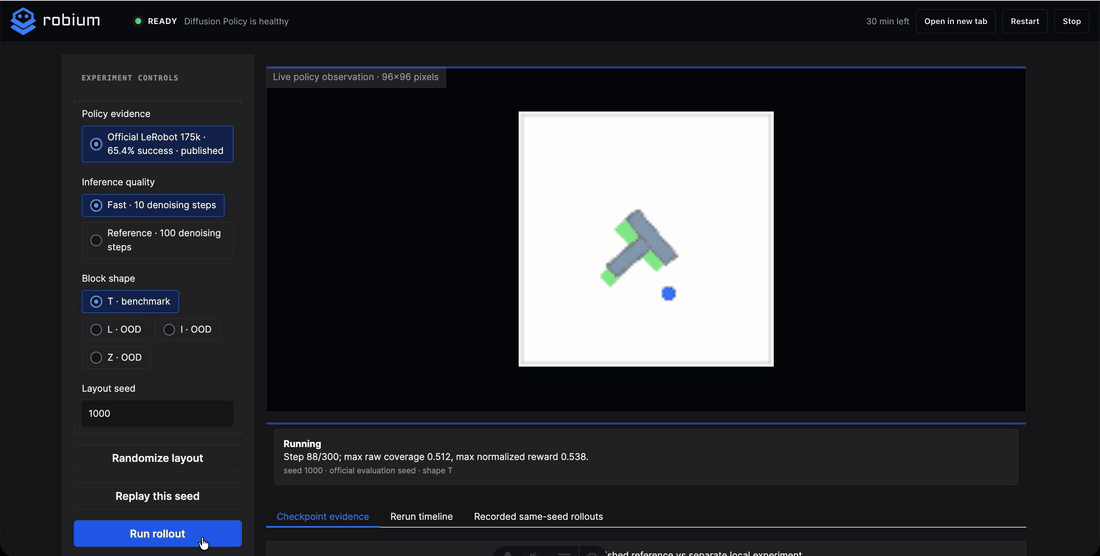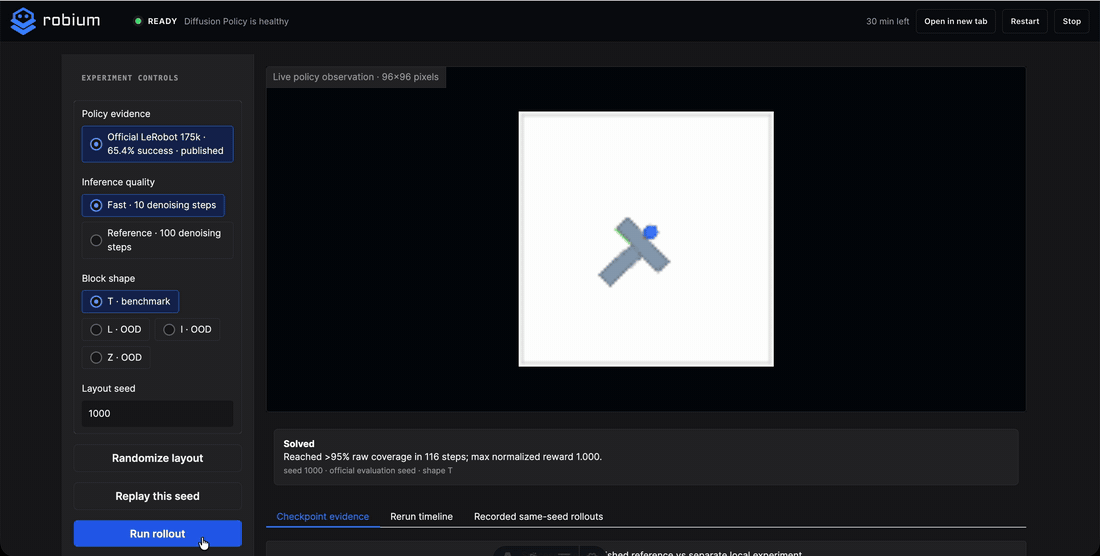
Running Diffusion Policy on PushT from a laptop
Run a compact, verified robot-learning experiment on a Mac, then use it to understand when ACT, Diffusion Policy, or a VLA fits.
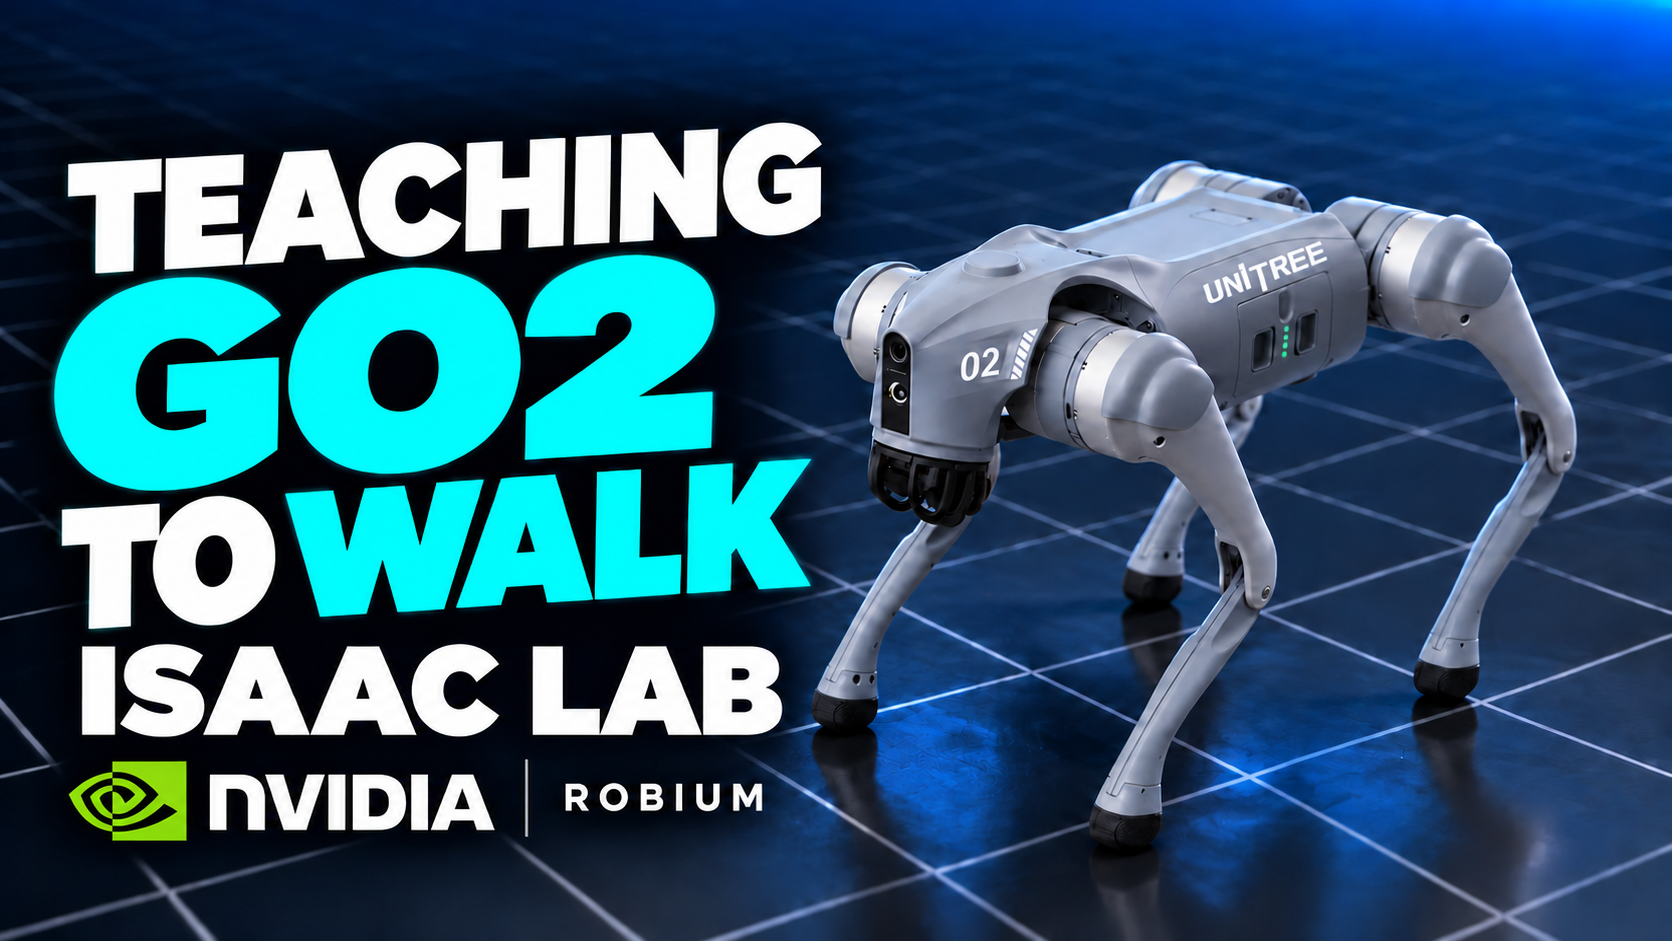
Training a Unitree Go2 to walk with Isaac Lab, checkpoint by checkpoint
A recovered Isaac Lab run turns policy training into a recorded progression, backed by a fresh capability-scoped GPU smoke.
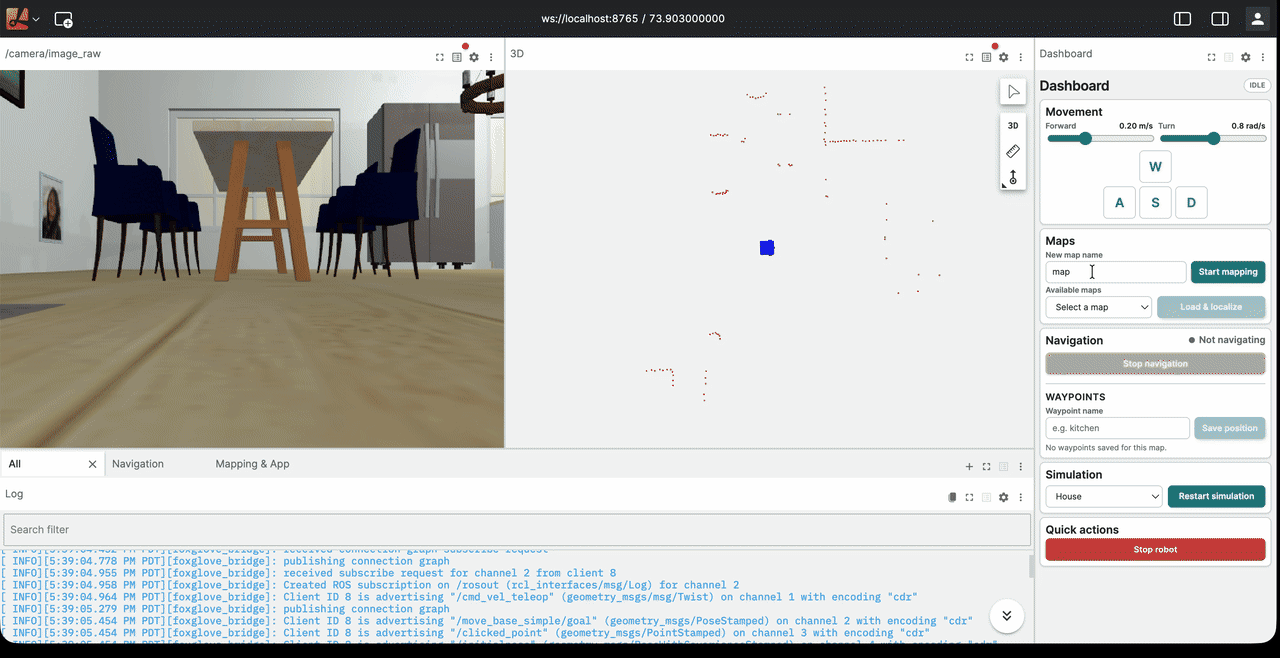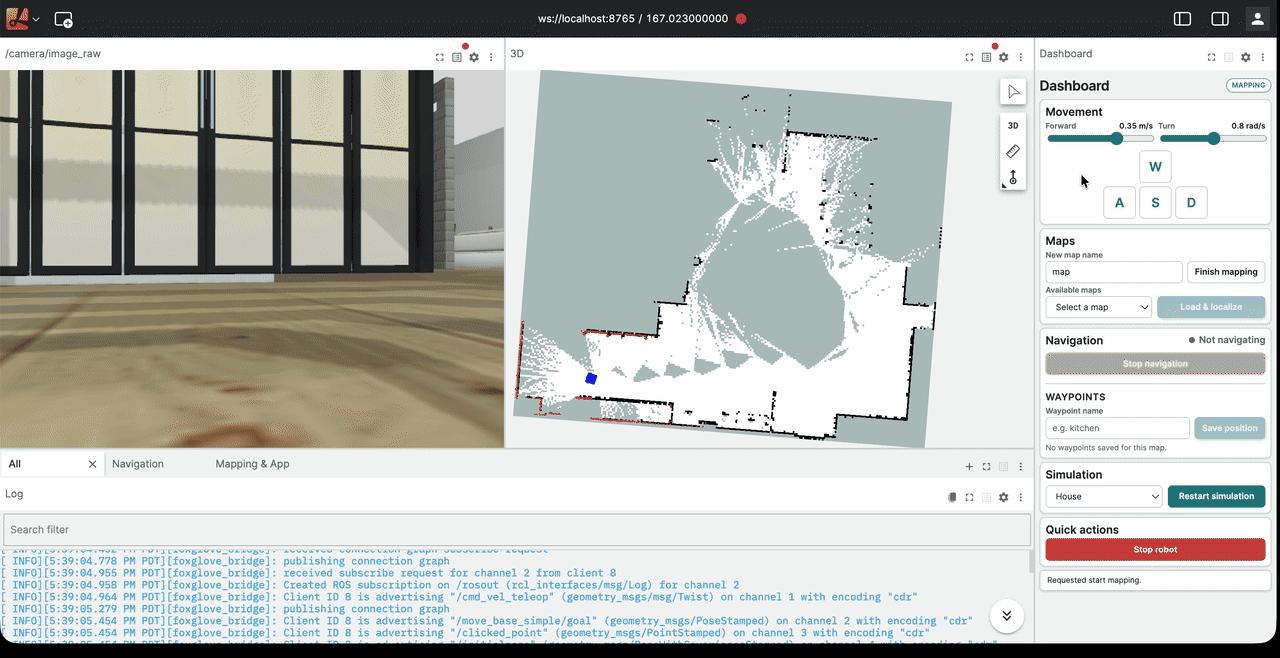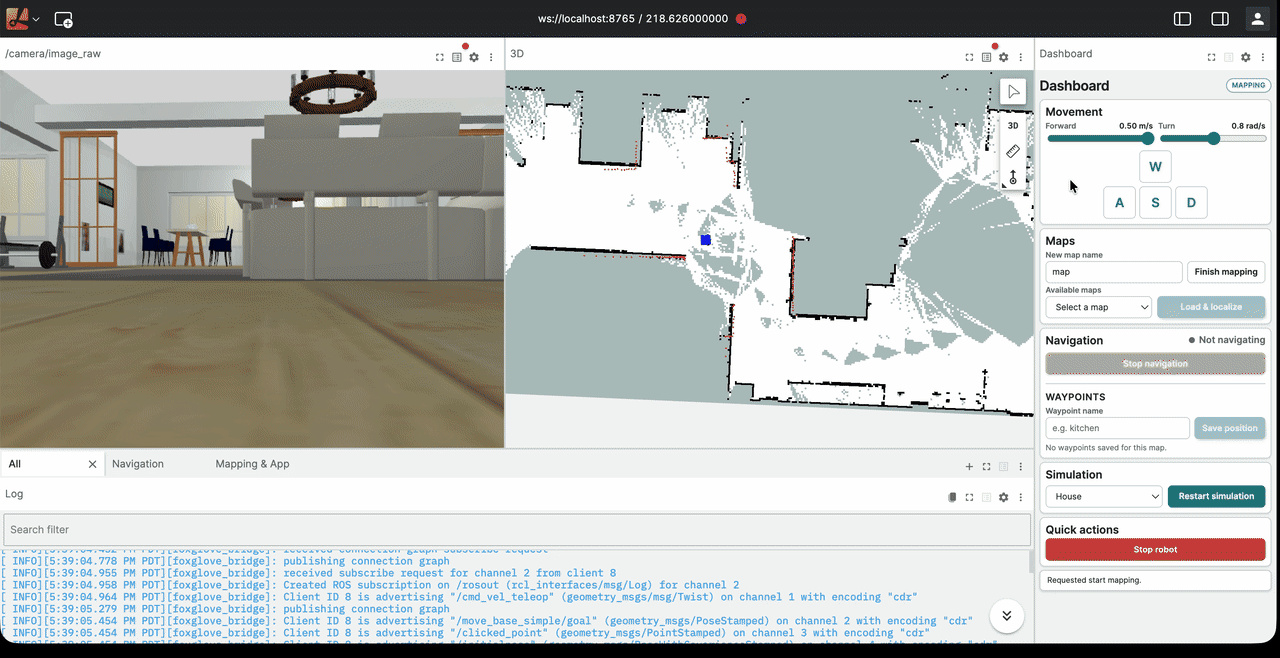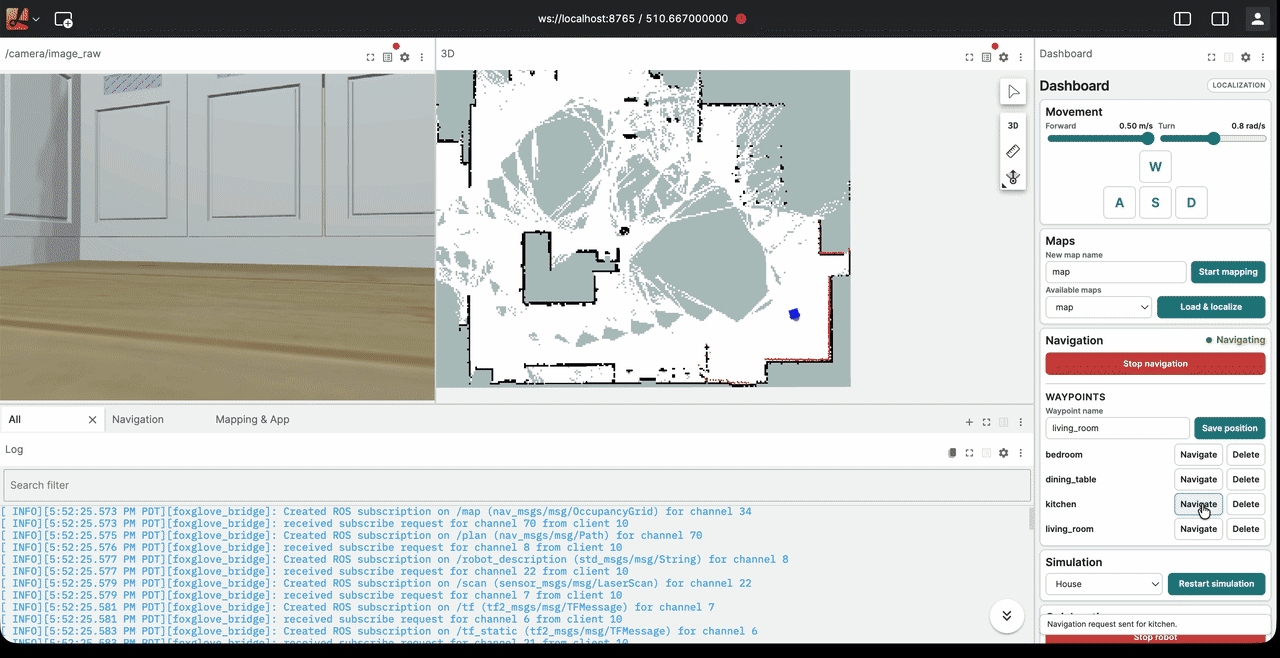
Mapping and navigation with ROS 2, from one app
Map a simulated TurtleBot3 with SLAM Toolbox, reuse the map with AMCL, save waypoints, and send Nav2 goals from a browser.
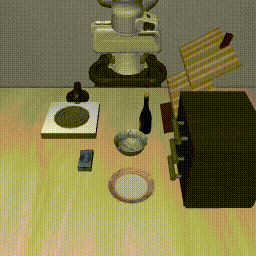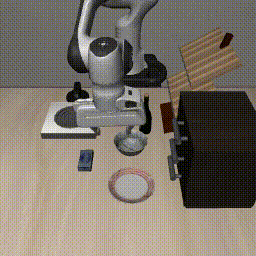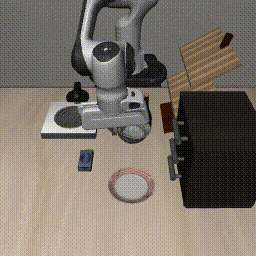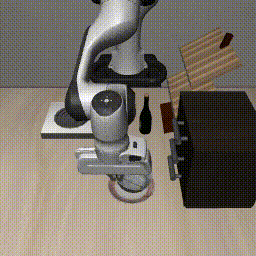
Running a Pi0.5 VLA pick-and-place policy with a Franka Panda
See how Physical Intelligence's Pi0.5 turns camera views, robot state, and a language instruction into actions for a simulated Panda arm.